Event-based imaging for Lagrangian particle tracking using continuous illumination
S. Brückner(1), M. Barnes(2), M. Hilfer(1), D.E. Rival(1,2)
1: Institute of Fluid Mechanics, TU Braunschweig, Germany
2: Department of Mechanical Engineering, Queen’s University, Canada
DOI:
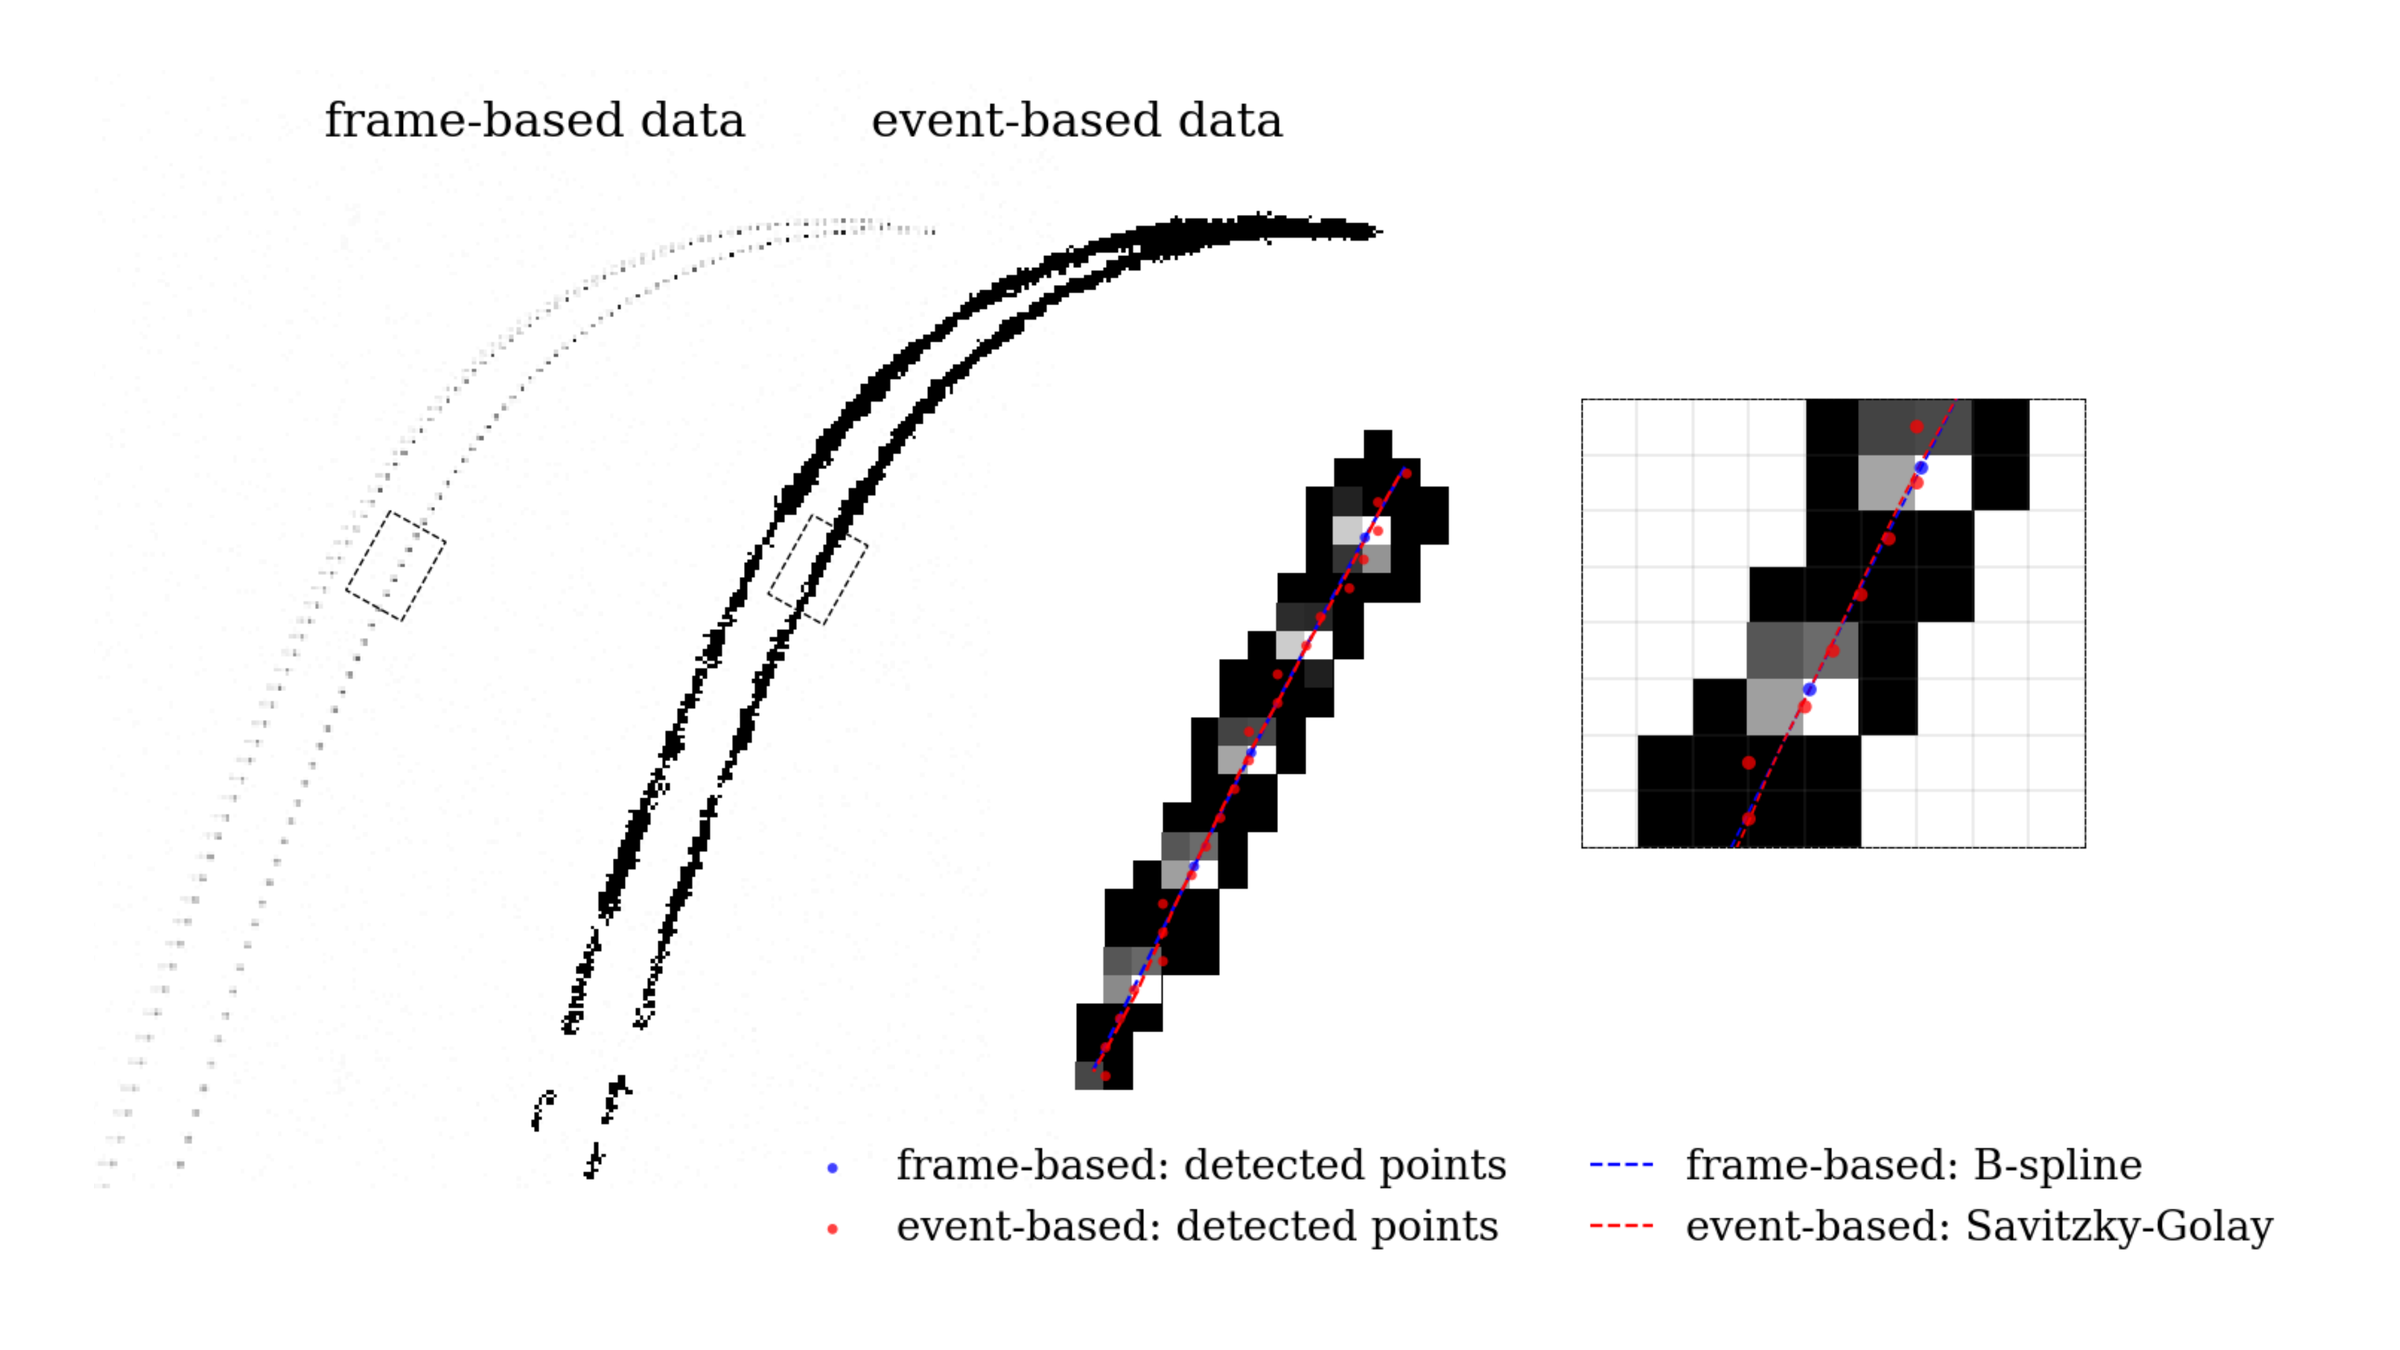
The objective of the current study is to quantitatively assess the position error obtained from event-based data by comparing with frame-based data as ground truth. To this end, a turbulent flow is seeded with air-filled soap bubbles imaged simultaneously by an event-based and a frame-based sensor. For the event-based data, a fit-based approach using Savitzky–Golay filtering is implemented. The distribution of the local error is characterized, and a mean position error of ē = 0.31 px, a standard deviation of σ = 0.19 px, and a RM SE = 0.36 px are reported, suggesting that sub-pixel position information can be recovered from event-based data through fit-based particle track reconstructions. Furthermore, velocity, acceleration, and radius-of-curvature statistics are derived to demonstrate the potential of event-based methods for reconstructing Lagrangian statistics. Key findings • The objective of the study is to quantitatively assess the position error obtained from event based data by comparing with frame-based data as ground truth. • A mean position error of ē = 0.31 px, a standard deviation of σ = 0.19 px, and a RM SE = 0.36 px are reported, suggesting that sub-pixel position information can be recovered from event-based data through fit-based particle track reconstructions. • Velocity, acceleration, and radius-of-curvature statistics are derived to demonstrate the po tential of event-based methods for the reconstruction of Lagrangian statistics.