Physically Consistent Free-Hand Calibration for Polynomial Camera Models
P. Sperotto, B. Watz, D. Hess
Dantec Dynamics A/S, Denmark
DOI:
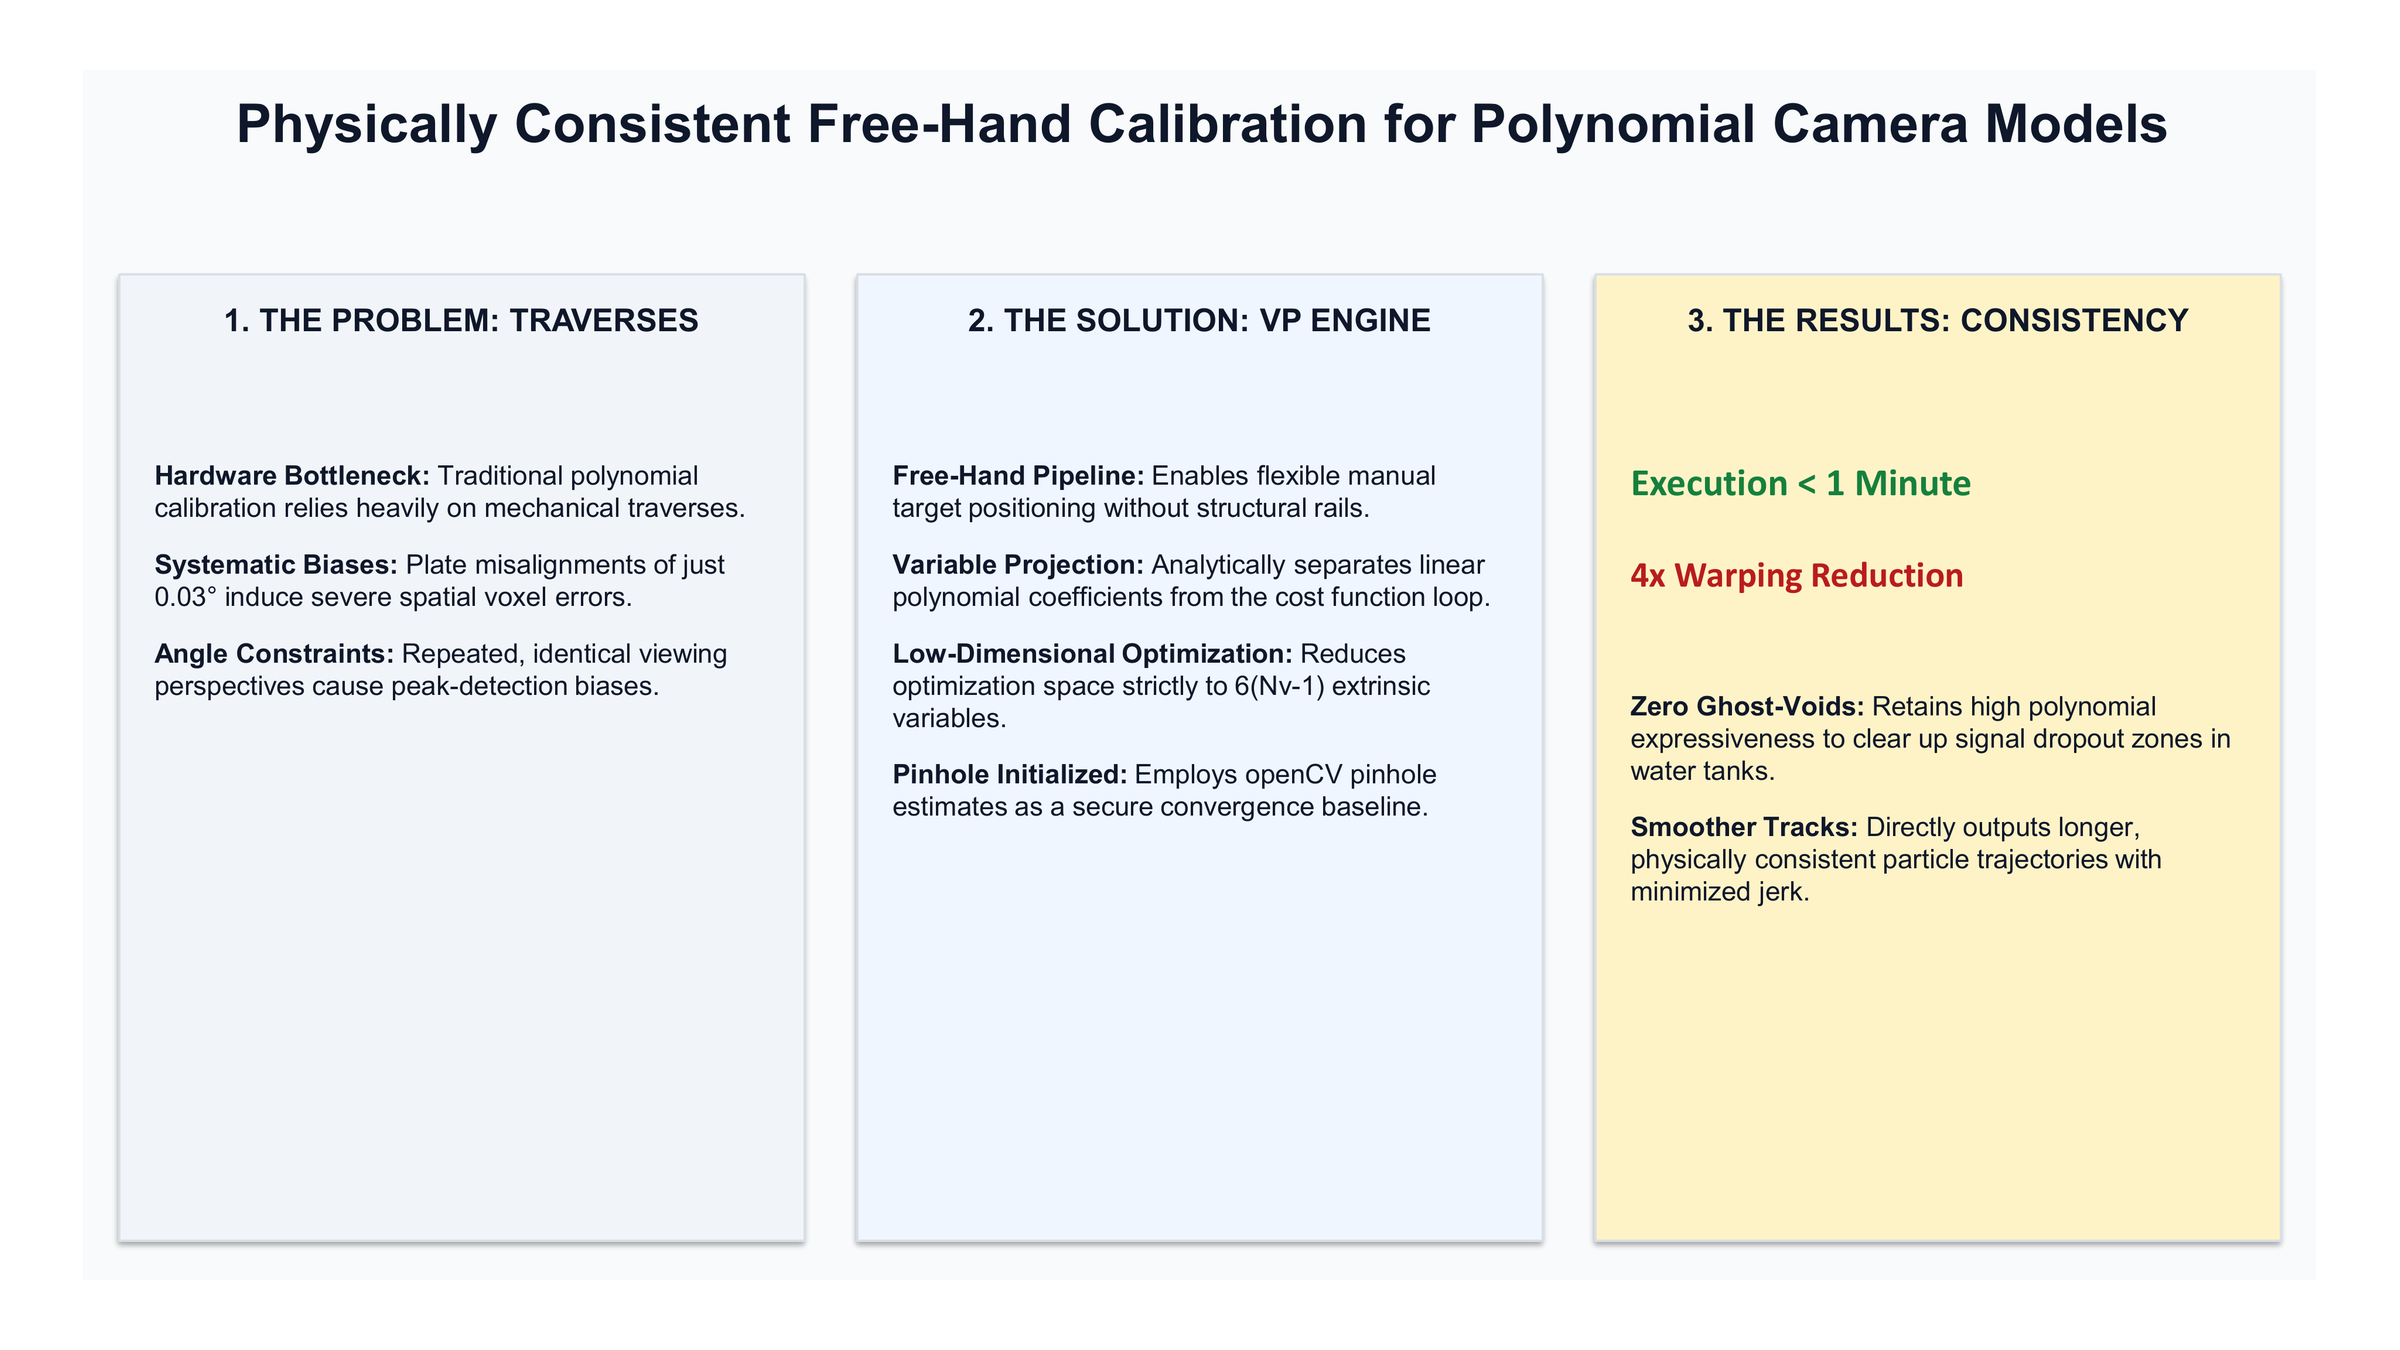
Polynomial camera models, such as the Soloff formulation, are widely used in volumetric imaging and particle-based velocimetry due to their flexibility. However, they lack clear separation between intrinsic and extrinsic parameters, which makes classical calibration challenging due to the necessity of a traversing system. In this work, we introduce a free-hand multi-camera calibration pipeline that reproduces the physically consistent behavior of pinhole-based methods. While, preserving the expressive power of purely mathematical camera models. The approach is demonstrated on the Soloff model but is applicable to any projection function that can be expressed as a nonlinear basis f (X) multiplied by a coefficient matrix A. Both synthetic and experimental results confirm that the proposed formulation preserves geometric consistency.